Critical hazards
- Wrong-way drivingmoves against the lane vector for 5 consecutive frames → critical alarm
- Stopped vehicle<10 px movement for 40 s at ≤2 km/h inside a lane
- Vehicle accident≥3 vehicles stopped within a tight spatial cluster
Open to opportunities · Pune, India
I build computer vision that watches real highways.
Software Engineer (AI/ML) at Arya Omnitalk (Arvind Group). I design the detection, tracking and incident pipelines behind live highway traffic management — VIDES, ATMS and TMCS — processing 50,000+ events a day at 95% model accuracy.
now> AI Engineer @ Arya Omnitalk
01 About
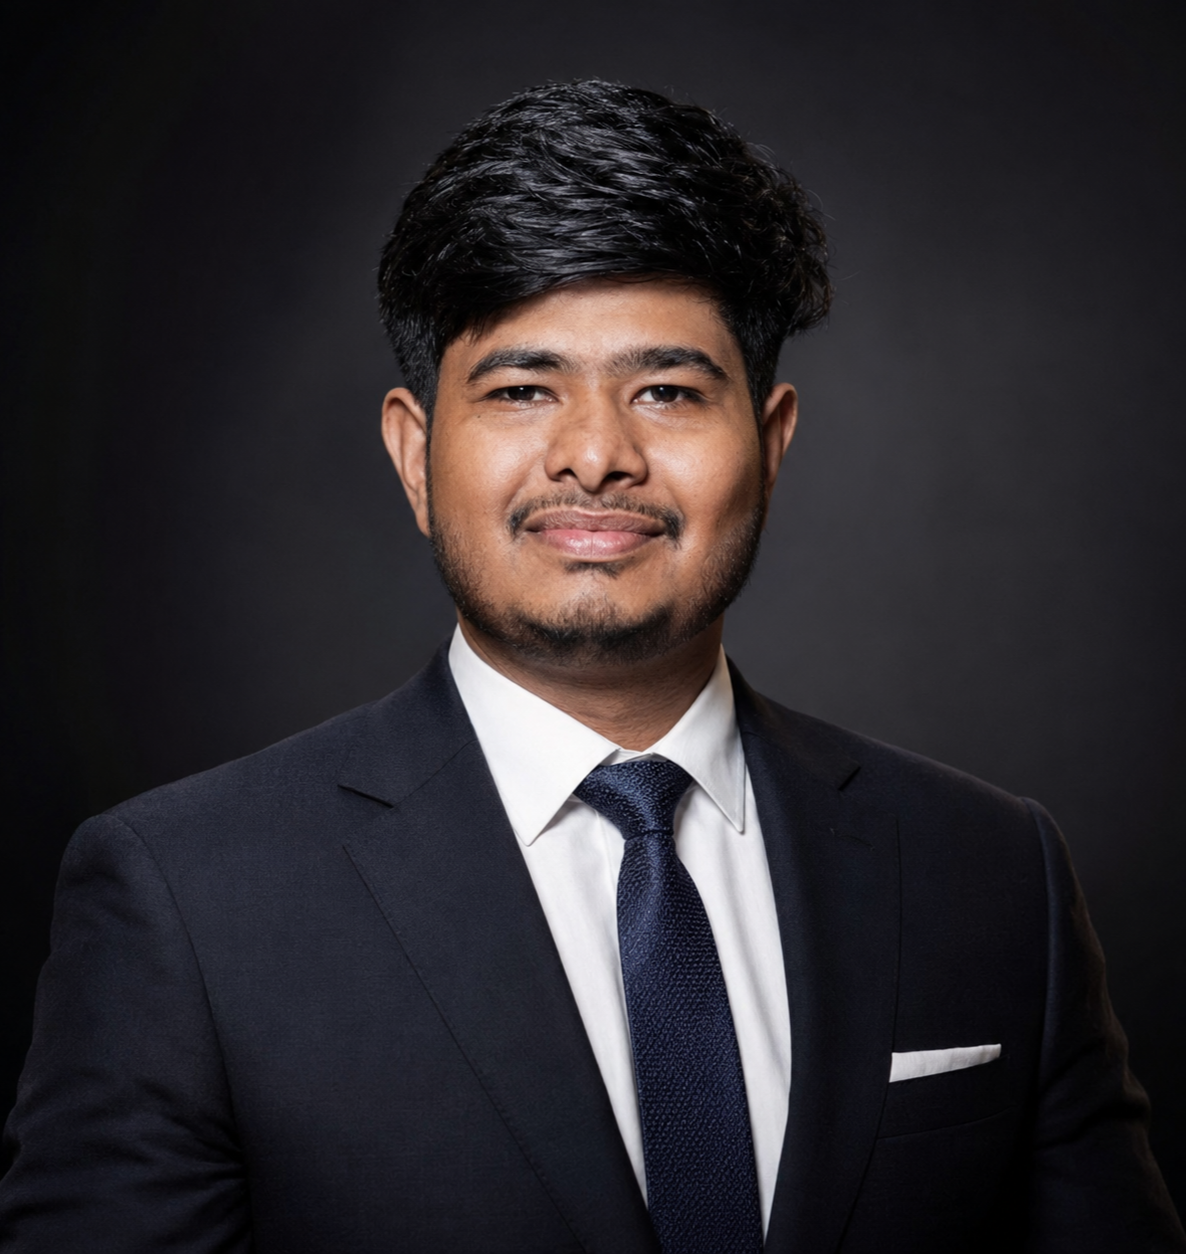
I'm an AI Engineer at Arya Omnitalk Wireless Solutions (part of the Arvind Group), where I design and deploy computer vision and generative AI systems for India's live highway infrastructure.
My work sits where models meet messy reality: PTZ cameras that move, headlights at 2 a.m., riders who look like pedestrians, cameras that drop off the network. My systems handle 50,000+ events daily at 95% accuracy with inference under 100 ms, and I engineered 30× faster vector retrieval with FAISS IVF indexing to serve 150,000+ forensic vehicle queries a day.
Before that I was a National Champion (AIR 1) at Smart India Hackathon 2023 as team lead, interned at IBM and MathWorks, and shipped an alumni portal my college still runs. B.E. in Electronics & Telecommunication, SPPU, 2025.
02 Experience
Arya Omnitalk Wireless Solutions Pvt. Ltd. (Arvind Group) · Pune · Full-time, on-site
AICTE · VOIS for Tech · Vodafone Idea Foundation · Remote
GeeksforGeeks · Ahilyanagar · Campus Leadership
IBM India Pvt. Ltd. · Bangalore / Remote · Technical Internship
MathWorks · Ahilyanagar / Pune · Technical Internship
Dr. Vithalrao Vikhe Patil College of Engineering · Savitribai Phule Pune University (SPPU)
03 Flagship case study · Arya Omnitalk
VIDES (Vehicle Identification & Detection System) is the ATCC and traffic-enforcement platform for expressway gantries and toll corridors. Each gantry runs its own NVIDIA Jetson Orin node: camera streams are decoded straight into GPU memory, every vehicle is detected, tracked, classified and plate-read, and violations and incidents are confirmed at the roadside. The control room receives structured, evidence-backed events — not raw video.
Most enforcement systems only wake up for violations. VIDES is built on complete verification: every clean passage is logged too, with class, speed, plate and evidence, so the corridor doubles as a fraud-resistant toll-auditing network.
Detection types
14
violations, incidents & audit
Models on one node
7
6 TensorRT FP16 engines + PP-OCRv4
Frame processing
<40ms
on-device, per stream
Edge → operator
<150ms
SSE → Socket.IO alert
Events per day
50K+
at 95% model accuracy
Vehicle classes
7
car · truck · bus · mini bus · auto · bike · tractor
Plate lock
2-read
OCR consensus before a plate is final
Decision timeout
6s
finalizer never waits on a slow model
Two camera roles share one perception core, then split into enforcement and incident paths.
ANPR / enforcement cameras
Overview / incident cameras
A
Streams decode straight into GPU memory via nvv4l2decoder. The Jetson Orin Nano has no hardware encoder, so a GStreamer tee forwards the original H.264 to live preview without re-encoding.
B
Each camera keeps only its latest 3 frames. If inference hiccups, stale frames are dropped rather than queued, so latency stays bounded instead of drifting behind real time.
C
ROI, lane, direction, size and track-quality filters drop irrelevant tracks before any expensive model runs — only vehicles that matter reach OCR, helmet or seatbelt inference.
D
CLAHE and sharpening before OCR, a Laplacian blur penalty, position-aware O/0 and I/1 fixes, and a plate only locks after 2 matching reads.
E
ANPR, helmet and seatbelt run in parallel worker pools on bounded queues. A finalizer fuses their results per vehicle with a 6 s timeout, so one slow model never stalls a record.
F
TensorRT engines share a GPU lock so contexts never collide on 8–16 GB Jetsons. RT-DETR runs every 3rd frame and pothole scans hourly, keeping the whole stack inside the power and memory budget.
G
All writes go through an async DB writer. The dashboard relay reconnects with exponential backoff and keeps a rolling per-camera cache, so operator screens load instantly without hitting the database.
H
Every violation reaches an operator with evidence to verify or discard — discards are retained for audit. Admin, operator and viewer roles gate who can change ROIs, cameras and thresholds.
| Central / cloud ATCC | VIDES edge node | |
|---|---|---|
| Latency | network round-trip before any decision | decided at the gantry in <40 ms |
| Bandwidth | continuous raw-video uplink | structured events + evidence crops |
| Privacy | raw footage leaves the site | frames processed on-site; only evidence kept |
VIDES is a proprietary Arya Omnitalk system. Source code, deployment sites and internal documentation are confidential; the architecture and figures above are shared at a level suitable for public discussion.
04 Flagship case study · Arya Omnitalk
TMCS (Traffic Monitoring Camera System) converts live IP/PTZ camera streams into explainable, evidence-backed incident events, built against NHAI's ATMS Standards & Specifications (Oct 2023), which place monitoring cameras roughly every kilometre of national highway. It is the detection layer beneath the highway ATMS: it does the continuous watching and hands the control room a structured, versioned, audit-traceable event — not a raw video feed to be reinterpreted later, under pressure.
A control room can't scale headcount with camera count. TMCS closes that gap at the camera, across multi-vendor ONVIF hardware, day and night — without replacing the cameras already installed.
Read the solution overview PDF · 14 pagesCamera feed → confirmed incident. Nothing becomes an alert until every stage agrees.
Pipeline latency (tracker + rules, excl. model)
p50 per frame. Scales roughly linearly with scene density.
Inference target
≤45ms p95
Dual-model, TensorRT FP16/INT8
Preset sync
2,500 → <10ms
−99.6% via one batched SQL upsert
Dead-camera rejection
0.1ms
vs. 10–30 s socket timeouts
Shutdown
<0.5s
from 10–30 s thread hangs
Analytics SQL load
−90%+
60 s in-memory TTL aggregation
Automated tests
298+
unit, integration, fault-injection
Track retention
60s
pedestrians & animals behind trucks
False pedestrian alarms
−95%+
rider-aware occupant tagging
A
YOLOv8 for vehicles plus RT-DETR for pedestrians, animals and debris, merged with class-agnostic NMS — each model does what it's best at, on one GPU-resident engine cycling across cameras.
B
ByteTrack with a dt-aware Kalman filter (xyah). Category-aware retention keeps a pedestrian's or animal's identity for up to 60 s while a truck passes in front.
C
Spatial occupant tagging geometrically links people to two-wheelers and auto-rickshaws, cutting false pedestrian alarms by over 95%.
D
EMA frame-luma tracking and an HSV saturation filter reject headlight glare and wet-road reflections. At night the bar for new tracks rises by +0.15, while confirmed tracks keep normal thresholds. No wall-clock assumptions — tunnels are dark at noon.
E
Every PTZ move or preset recall clears tracks and pauses analytics until the camera stabilizes, then loads that preset's own ROIs. A moving camera never fires a false wrong-way against the wrong geometry.
F
An ONVIF supervisor with a 20 s circuit breaker keeps dead cameras from blocking async workers. Re-entrant locks and a watchdog guarantee deterministic shutdown; Pelco-D presets fall back to AbsoluteMove.
G
Write-once evidence with a SHA-256 digest, never edited by later processing. Boxes, track ID and class are rendered as an overlay on the untouched image, and every event records the exact model, rule and scene-config versions that fired it.
H
Shares the master VMS/ATCC database through a synchronized view, so it coexists with legacy systems with zero downtime. RBAC with 36 permissions across 6 domains and 5 role tiers, cached with instant invalidation and full audit logging.
Car · Motorcycle · Truck · Bus · Mini bus · Auto-rickshaw · Tractor · Bicycle · Pedestrian · Animal · Road debris
TMCS is a proprietary Arya Omnitalk system. The linked overview is Arya Omnitalk's client-facing solution document; source code and client deployment details stay confidential, and figures above are internal engineering benchmarks and acceptance targets.
05 Selected work
ATCC and enforcement on NVIDIA Jetson Orin at every gantry: detection, tracking, ANPR, helmet, triple riding, seatbelt, speed, wrong-way, accident, pedestrian, animal and pothole detection — confirmed at the roadside and streamed to operators in under 150 ms.
Incident detection on live PTZ cameras: dual-model detection, occlusion-resilient tracking, 7 incident rules and tamper-evident evidence for the ATMS control room.
Multi-modal vehicle retrieval combining ResNet + OSNet embeddings, OCR'd plates and vector search. FAISS IVF indexing made retrieval 30× faster, serving 150K+ forensic queries a day at 99.9% uptime.
Local-first dataset platform for model-assisted annotation: YOLOv8/11 auto-labelling, box and polygon instance segmentation, 5-point dataset QA and in-browser fine-tuning with live SSE logs. Auto-annotates 100,000 images in 30 minutes on a Jetson Orin NX 16 GB.
Decision-intelligence platform acting as a "smart city brain": multi-agent orchestration (Gemini 2.5) to assess risk, a digital-twin simulator, and explainable AI for transparent policy recommendations.
Multi-modal incident intelligence fabric. Correlates high-velocity signals from IoT, cameras and microphones with an agentic workflow engine to validate anomalies and generate safety guardrails in real time.
Document AI + RAG platform with hybrid retrieval (FAISS + BM25 + RRF), streaming Q&A, a knowledge graph explorer and analytics. Handles PDF, DOCX, XLSX, images and web URLs with sub-2 s answers.
Local-first adaptive typing trainer built on a 10-agent deterministic AI architecture with no cloud dependency: sub-millisecond telemetry, O(1) DOM updates, ghost racing and Web Audio synthesis, shipped as an 18 MB standalone executable.
Role-based alumni networking platform, officially adopted by the college and serving 500+ alumni. Four dashboards (Alumni, Mentor, Coordinator, Admin), JWT auth, XSS/CSRF protection, 164+ commits.
National-champion system from Smart India Hackathon 2023: IoT smart bins with AI device identification, GPS tracking, weight and fill-level sensing, a real-time analytics dashboard and a citizen mobile app.
IoT irrigation with ML-driven water optimization from real-time soil-moisture sensors and weather APIs. University Rank 2, SPPU Startup Olympiad 2025.
06 Toolkit
07 Recognition
AIR 1
Team Lead · AI E-Waste Management System
Led the team to national victory with an AI system for automated waste classification — selected as the best solution from thousands of teams across India.
Rank 2
University level · AI Smart Irrigation (JalTantra)
Predictive ML for water optimization — IoT and AI integration for precision agriculture.
Runner-up
Global · AI Investment Intelligence
Risk-based scoring and data-driven financial recommendations for AI portfolio insights.
08 Writing
09 Contact
Open to AI / computer vision roles, projects and collaborations. I usually reply within 24 hours.